Xintong Yang
Postdoctoral Research Associate · 卡迪夫大学合作成员
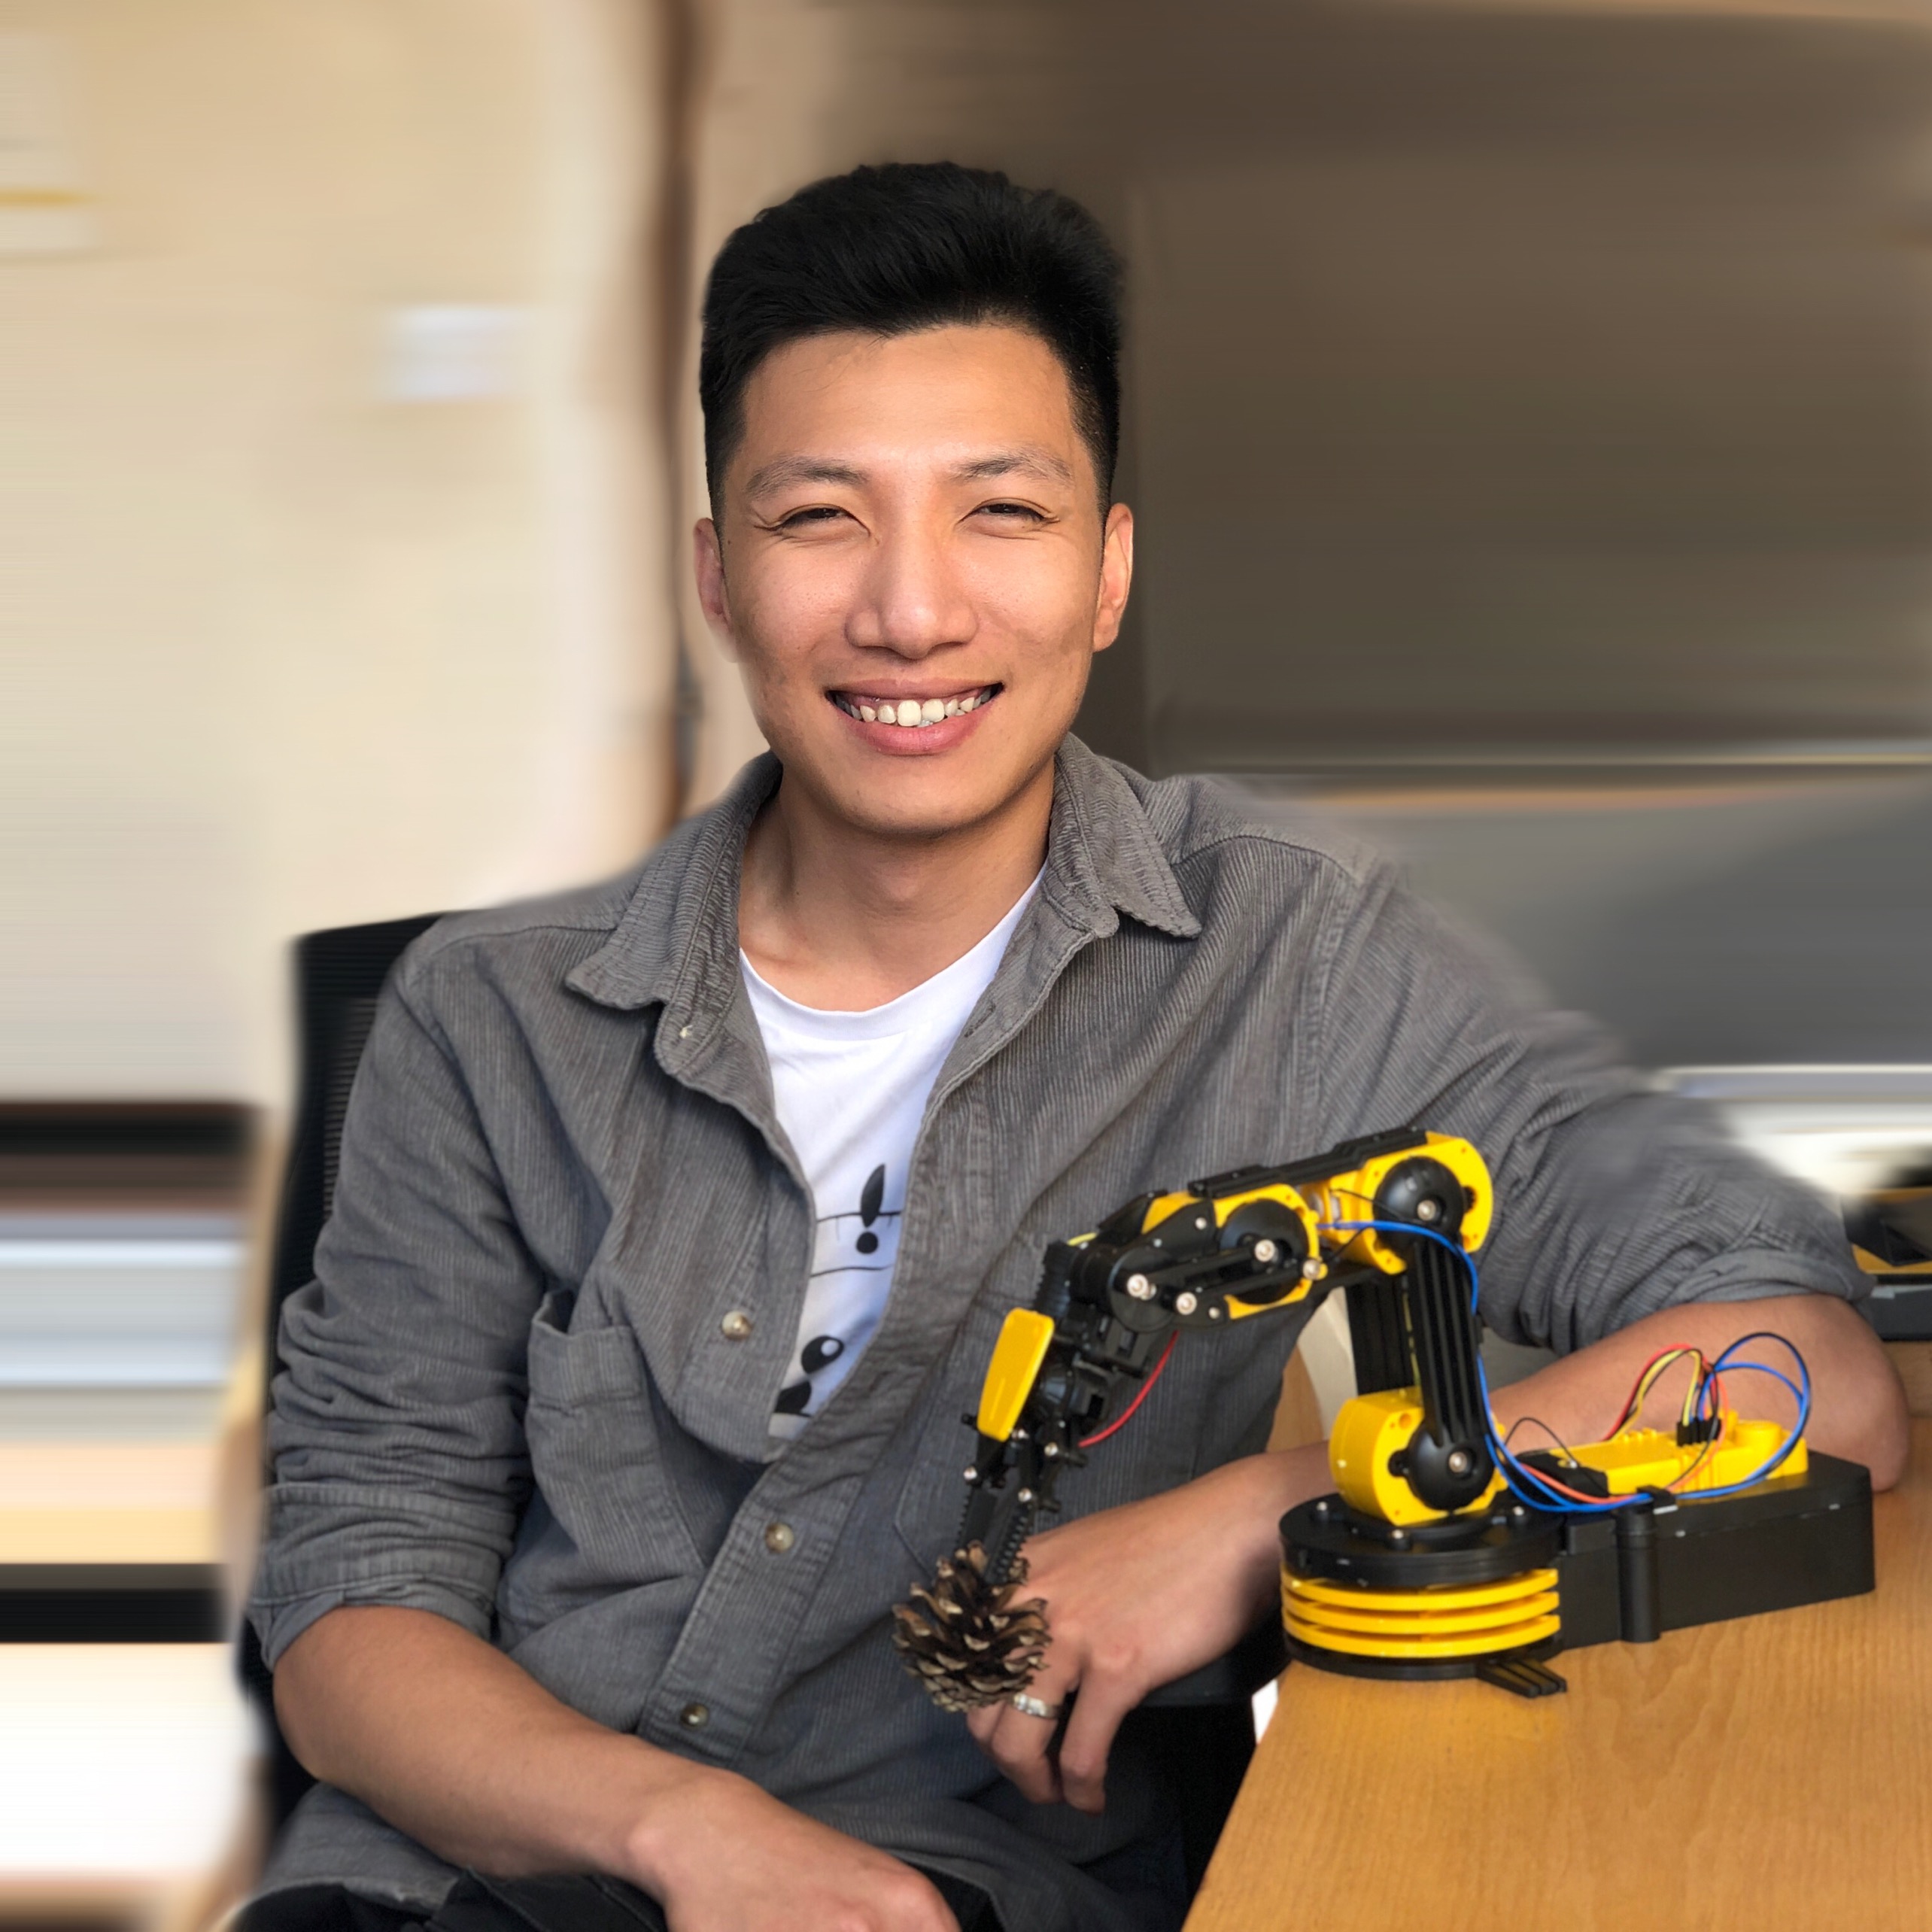
Xintong Yang
博士后研究员 · 卡迪夫大学工程学院 / 药学与制药科学学院博士(英国卡迪夫大学)· 机器人与自主系统实验室负责人 · 卡迪夫大学合作成员
个人简介
Xintong Yang 博士是英国卡迪夫大学(Cardiff University)工程学院博士后研究员,同时任职于药学与制药科学学院,并担任机器人与自主系统实验室(Robotics and Autonomous Systems Lab, C1.06, Queen's Building)负责人。
他于 2023 年在卡迪夫大学工程学院获博士学位,师从 Ze Ji 教授,博士课题为《基于层级强化学习与可供性学习的机器人操作》。此前于广东工业大学机械与工业工程学院先后获得学士与硕士学位,硕士期间研究运筹学、混合整数规划、蚁群优化与护士路径问题。
他的研究致力于让机器人能够可靠地操作真实世界中的刚体、可变形体及颗粒介质,研究方向涵盖机器人操作、可微分物理建模、系统辨识、强化学习、可供性学习、具身智能与科学发现机器人。他是自主机器人系统工程中“智能体化编程工具”的积极倡导者,希望通过结合大模型与机器人学习,加速实验室自动化与科学发现。
研究领域
教育与工作经历
- 2023 – 至今 英国卡迪夫大学工程学院,博士后研究员(Research Associate);机器人与自主系统实验室负责人
- 2023 – 至今 英国卡迪夫大学药学与制药科学学院,博士后研究员
- 2021 – 2023 英国卡迪夫大学工程学院,博士研究助理 / 助教
- 2019 – 2023 英国卡迪夫大学工程学院,博士(机器人操作:层级强化学习与可供性学习)
- 2016 – 2019 广东工业大学,机械与工业工程,硕士
- 2012 – 2016 广东工业大学,机械与工业工程,学士
科研项目
- Developing dRTP Leadership for Reliable AI-Driven Autonomous Laboratories,UKRI 资助,2026–2027,核心成员
- Cardiff-Xiamen Collaboration Fund,卡迪夫大学,2024,核心成员
- BBSRC 自动化/机器人化生物学实验室项目,2025,博士后研究员
- 多个关于颗粒介质操作、可微分物理挖掘机器人、弹性/塑性材料系统辨识的研究项目
代表性论文
- Yang, X., Lai, Y. and Ji, Z. Differentiable Physics-based System Identification for Robotic Manipulation of Elastoplastic Materials. The International Journal of Robotics Research (IJRR), 2025
- Yang, X., Wei, M., Lai, Y. and Ji, Z. DDBot: Differentiable Physics-Based Digging Robot for Unknown Granular Materials. IEEE Transactions on Robotics (T-RO), 2026
- Wei, M., Yang, X., Yan, J., Lai, Y.-K. and Ji, Z. Celebi's Choice: Causality-Guided Skill Optimisation for Granular Manipulation via Differentiable Simulation. IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2025
- Wei, M., Yang, X., Yan, J., Lai, Y.-K. and Ji, Z. Differentiable Skill Optimisation for Powder Manipulation in Laboratory Automation. IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2025
- Yang, X., Wu, J., Lai, Y. and Ji, Z. GAM: General Affordance-Based Manipulation for Contact-Rich Object Disentangling Tasks. Neurocomputing, 2024
- Yang, X., Ji, Z., Wu, J. and Lai, Y. Recent Advances of Deep Robotic Affordance Learning: A Reinforcement Learning Perspective. IEEE Transactions on Cognitive and Developmental Systems (TCDS), 2023
- Yang, X., Ji, Z., Wu, J., Lai, Y., Wei, C., Liu, G. and Setchi, R. Hierarchical Reinforcement Learning with Universal Policies for Multi-Step Robotic Manipulation. IEEE Transactions on Neural Networks and Learning Systems (TNNLS), 2022
- Yang, X. Robotic Manipulation via Hierarchical and Affordance Learning. PhD Thesis, Cardiff University, 2023
学术服务
- IEEE International Conference on Robotics and Automation (ICRA) 审稿人
- IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 审稿人
- IEEE Robotics and Automation Letters (RA-L)、Robotics and Computer-Integrated Manufacturing (RCIM)、IEEE TCDS、IEEE/ASME Transactions on Mechatronics (TMech)、Proceedings of the IMechE 等期刊审稿人
- International Conference on Automation and Computing (ICAC) 元审稿人(Meta-reviewer)